DexHOT: Learning Hand–Object Configuration Transfer for Dexterous Manipulation
arXiv preprint · 2026 First author
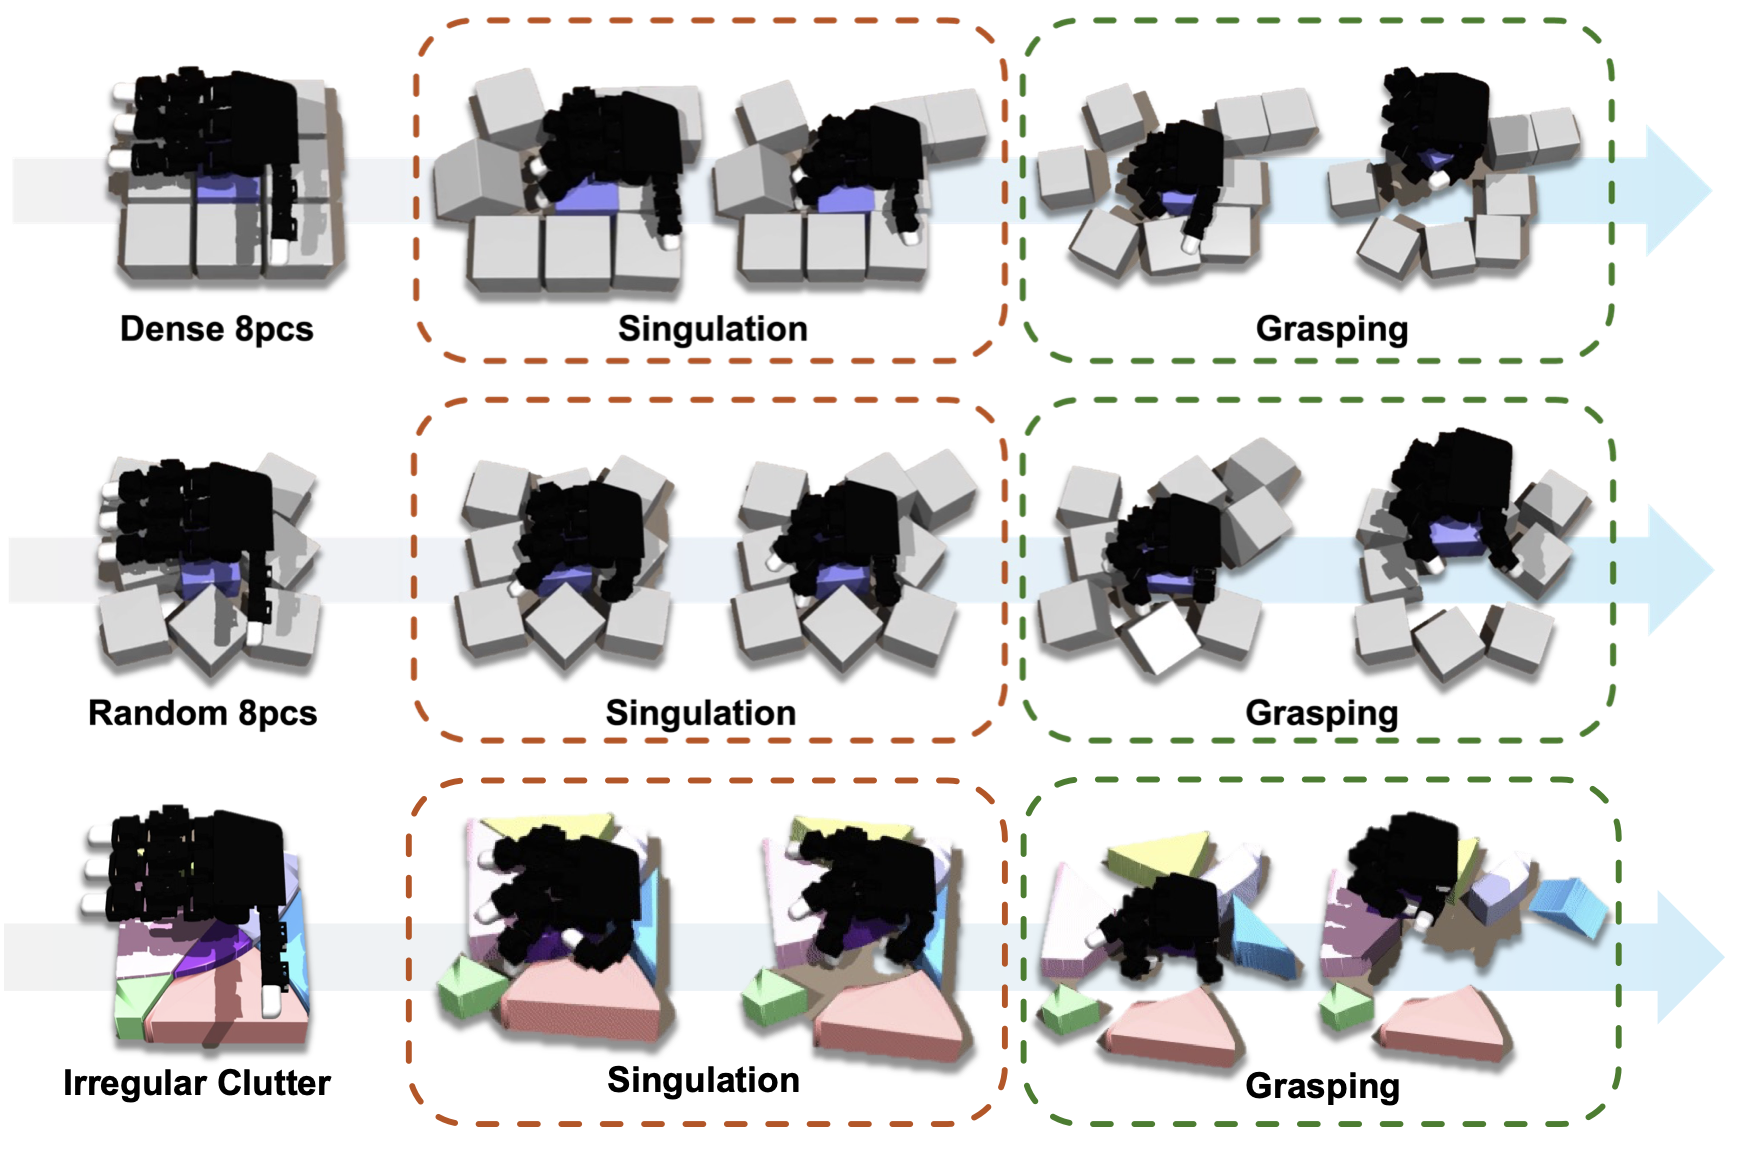
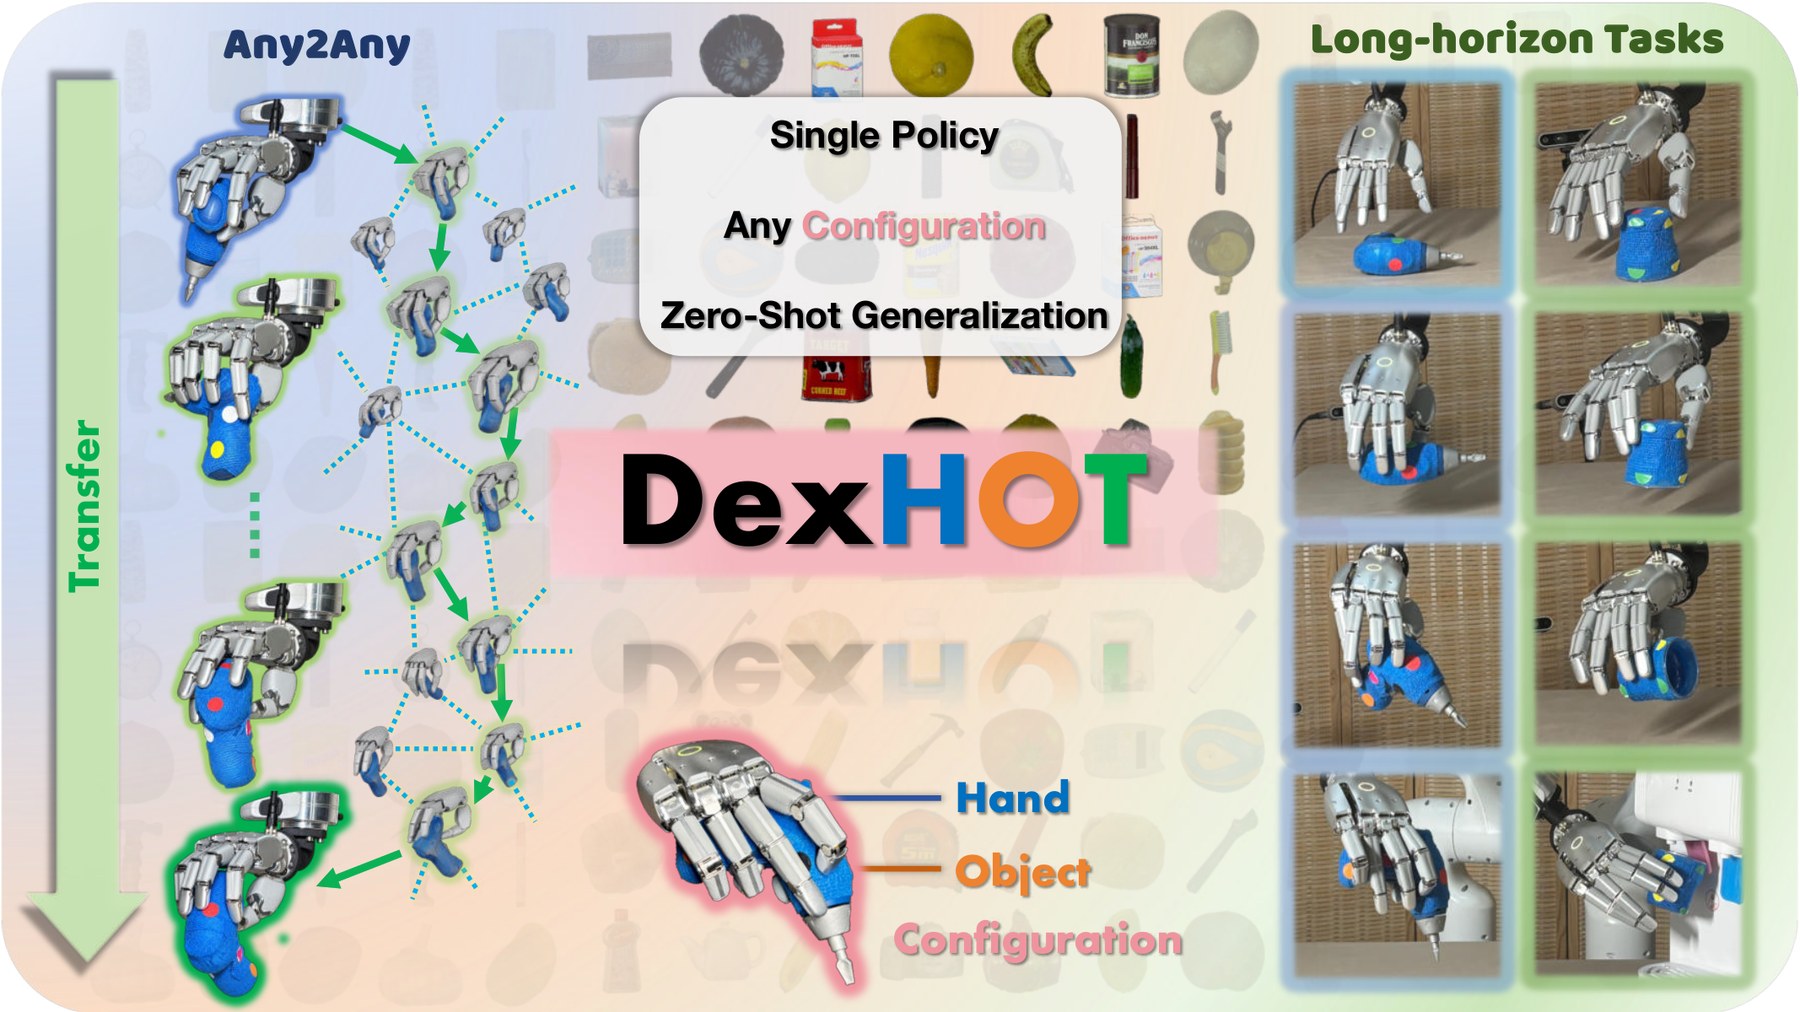
DexHOT learns a single relation-conditioned policy for dexterous hand–object configuration transfer from synthetic feasible configuration pairs, without human data during policy training. At deployment, configuration subgoals enable Any2Any transfers and human demonstration-guided long-horizon tasks. On DexHOTBench with 120 objects, it achieves 80.5% / 69.4% transfer success on seen / unseen objects in simulation, 61.5% over 200 real-robot transfers, and 90% task success across six long-horizon tasks.